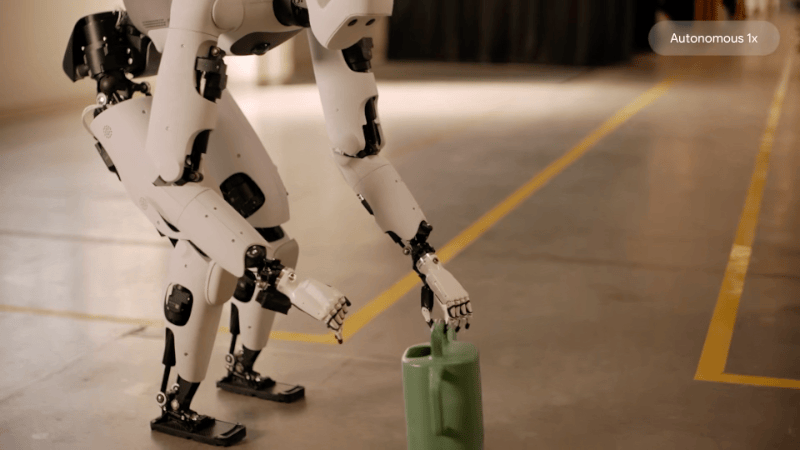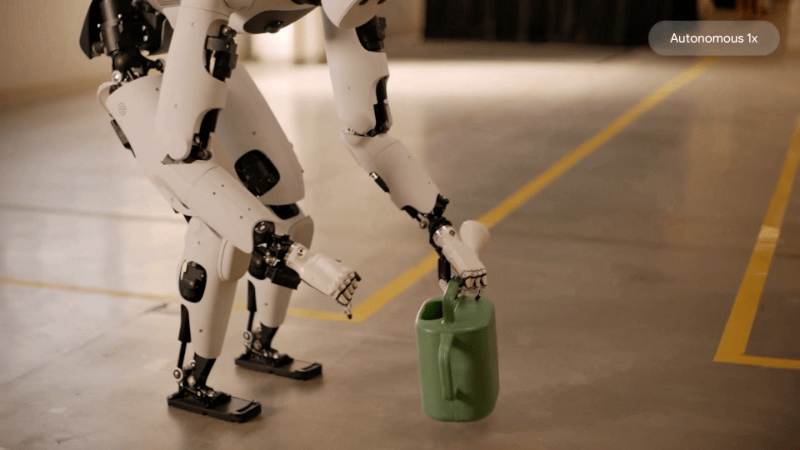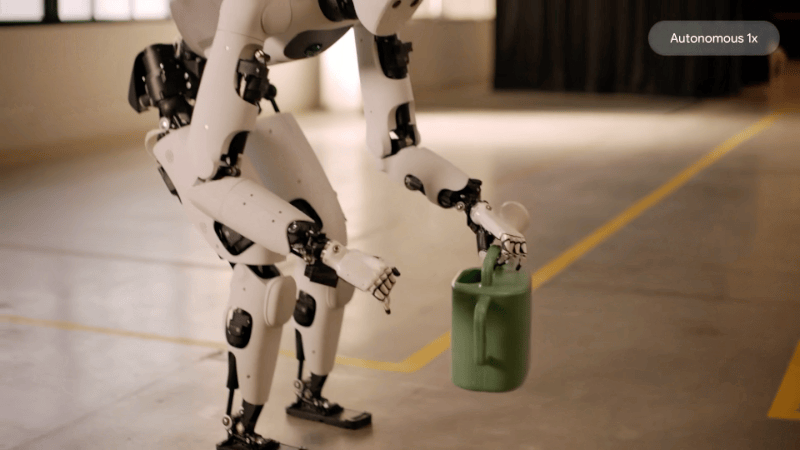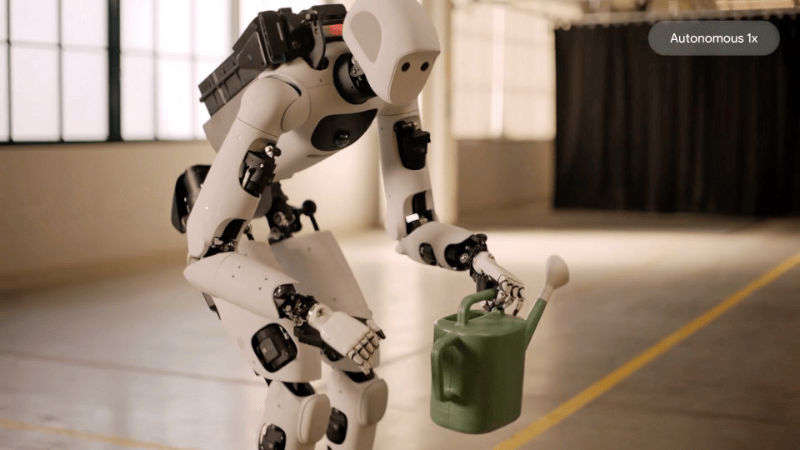
Google DeepMind推出了Gemini Robotics 2,一个主打"全身智能"的机器人通用模型1。该模型包含三个子模型:ER 2负责环境理解与任务规划,Robotics 2 VLA模型将视觉与语言转换为动作,On-Device 2则将动作模型本地化并可用少于200个样例在几小时内适配新机器人1。相比前代仅控制上半身的设计,新模型实现了机器人双腿、躯干、双臂和手指的协调控制,使其能够在移动中执行复杂操作1。
谷歌在实际应用测试中展示了该模型的性能。搭载五指灵巧手的Apollo 2机器人在从桌面、地面和货架取物的平均成功率分别达到68.4%、45.7%和76.3%1。在灵巧手任务中,拧下灯泡的成功率达92%,拧上灯泡36%,扎垃圾袋44%,使用簸箕32%,封自封袋40%1。搭载两指夹爪的机器人在通用抓放、工具配套和精密插入任务中的平均成功率分别为74.2%、78.9%和89.6%1。谷歌表示,同一模型已应用于搭载不同灵巧手的Apollo 2和使用两指夹爪的Franka Duo等多种机器人配置1。
Google DeepMind has introduced Gemini Robotics 2, a unified robot foundation model designed to enable coordinated control of entire robot bodies during task execution 1. The system represents a significant advance over previous generations, which were limited to controlling only the upper body, by enabling coordinated movement of a robot's legs, torso, arms, and fingers simultaneously 1.
The Gemini Robotics 2 architecture consists of three interconnected components 1. The ER 2 model handles environmental understanding and task planning, while the Robotics 2 Vision-Language-Action (VLA) model converts visual and linguistic inputs into motor commands 1. The On-Device 2 component localizes the action model onto individual robots and enables adaptation to new robot platforms using fewer than 200 sample demonstrations collected over just a few hours 1.
Performance metrics demonstrate the system's capability across diverse manipulation tasks. The Apollo 2 robot achieved average success rates of 68.4% for desktop object retrieval, 45.7% for ground-level picking, and 76.3% for shelf-based retrieval 1. When equipped with a five-fingered dexterous hand, the robot successfully unscrewed lightbulbs 92% of the time but managed to screw them back in only 36% of the time, with performance on other dexterous tasks including garbage bag sealing at 44%, dustpan use at 32%, and self-sealing bag closure at 40% 1. Systems using a two-finger gripper demonstrated higher success rates: 74.2% for general grasping and placement, 78.9% for tool-specific tasks, and 89.6% for precision insertion operations 1. Google reports that the same model has been successfully deployed across multiple robot platforms, including Apollo 2 robots equipped with different dexterous hands and Franka Duo robots using two-finger grippers 1.
评论
还没有评论,欢迎留下第一条。