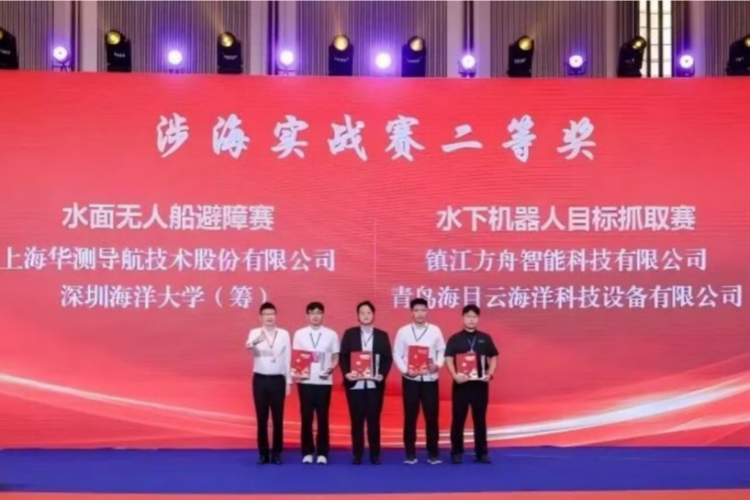
深圳海洋大学(筹)与南方科技大学联合研发的VLA端到端自动驾驶无人船项目在2026圳港杯海洋新质生产力创新大赛中荣获水面无人船自主避障赛二等奖1。本次大赛共有全国375个创新主体参赛,仅5支队伍获得该赛项奖项1。
该项目由南科大博士生李佳林带领团队完成,由讲席教授陈永顺指导1。无人船在深圳大铲湾的风浪、回流、密集浮标障碍等真实海域环境中实现了毫秒级环境感知和智能避障,全程零人工干预1。项目采用VLA具身智能技术,突破了传统无人船"感知—规划—控制"割裂的技术瓶颈1,在智能推理决策与机动避障方面实现了创新突破。
该技术方案可广泛应用于智能航运、海上风电运维、海洋生态监测、海上应急搜救等场景1,为海洋产业的智能化发展提供了新的技术支撑。
A team from Southern University of Science and Technology (SUSTech) and Shenzhen Ocean University (in preparation) has secured second place in the surface unmanned vessel autonomous obstacle avoidance competition at the 2026 Shenzhen-Hong Kong Cup Marine New Quality Productive Force Innovation Competition for their VLA end-to-end autonomous driving unmanned ship project 1. The achievement came from a field of 375 innovation entities nationwide, with only five teams receiving awards in the unmanned vessel autonomous obstacle avoidance category 1.
The unmanned ship, led by SUSTech doctoral student Li Jialin and guided by Chair Professor Chen Yongshun, successfully demonstrated millisecond-level environmental perception and intelligent obstacle avoidance in real marine conditions at Dashawan in Shenzhen, with zero human intervention throughout the operation 1. The vessel navigated through challenging conditions including wind, waves, backflow, and densely distributed floating obstacles by applying VLA embodied intelligence technology, overcoming the traditional disconnect between the "perception-planning-control" phases in conventional unmanned ship systems 1. The breakthrough technology can be deployed across intelligent shipping, offshore wind farm maintenance, marine ecological monitoring, and maritime emergency rescue operations 1.
评论
还没有评论,欢迎留下第一条。